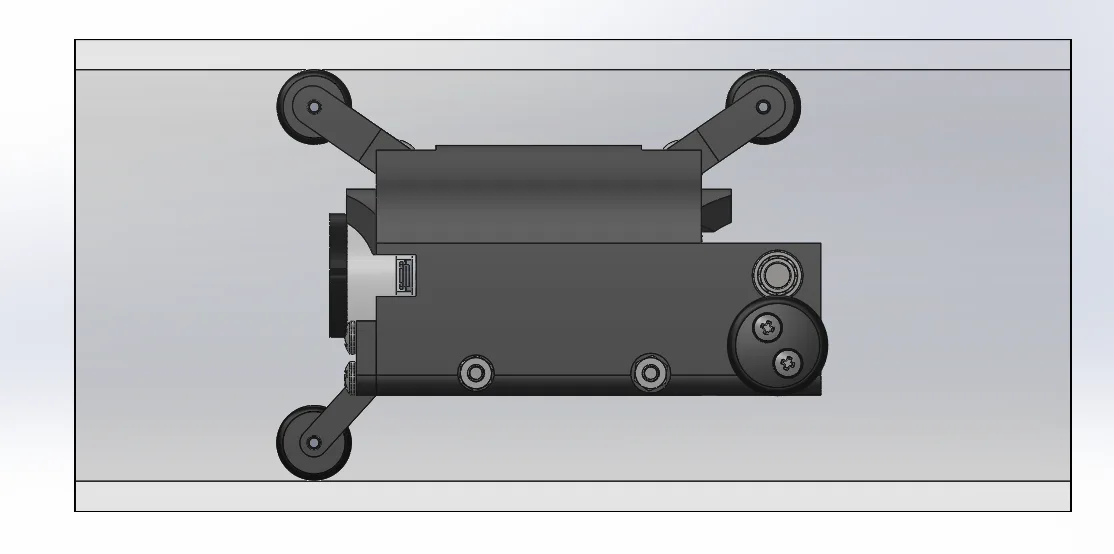
The in-pipe leak detecting robot autonomously navigates gas- and liquid-filled pipes and finds leaks much faster than standard methods, saving money, resources and the environment.
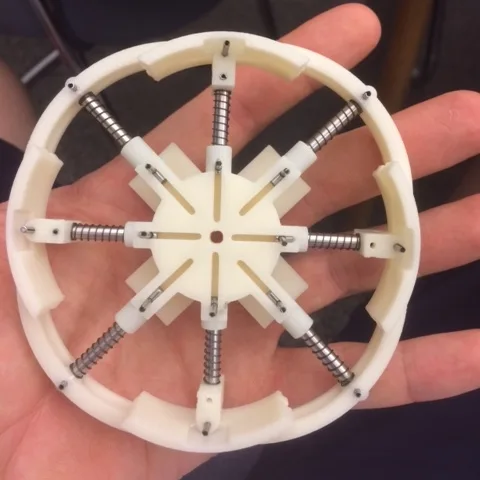
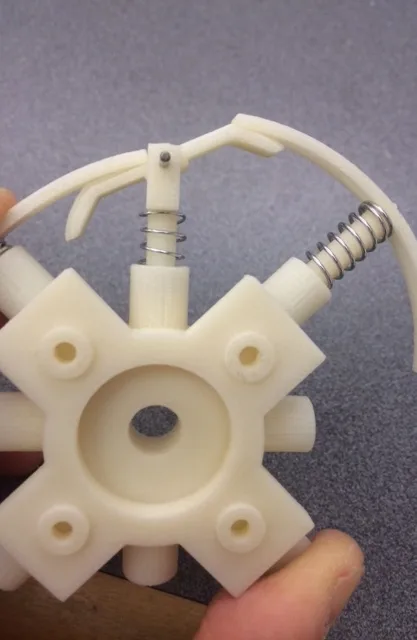
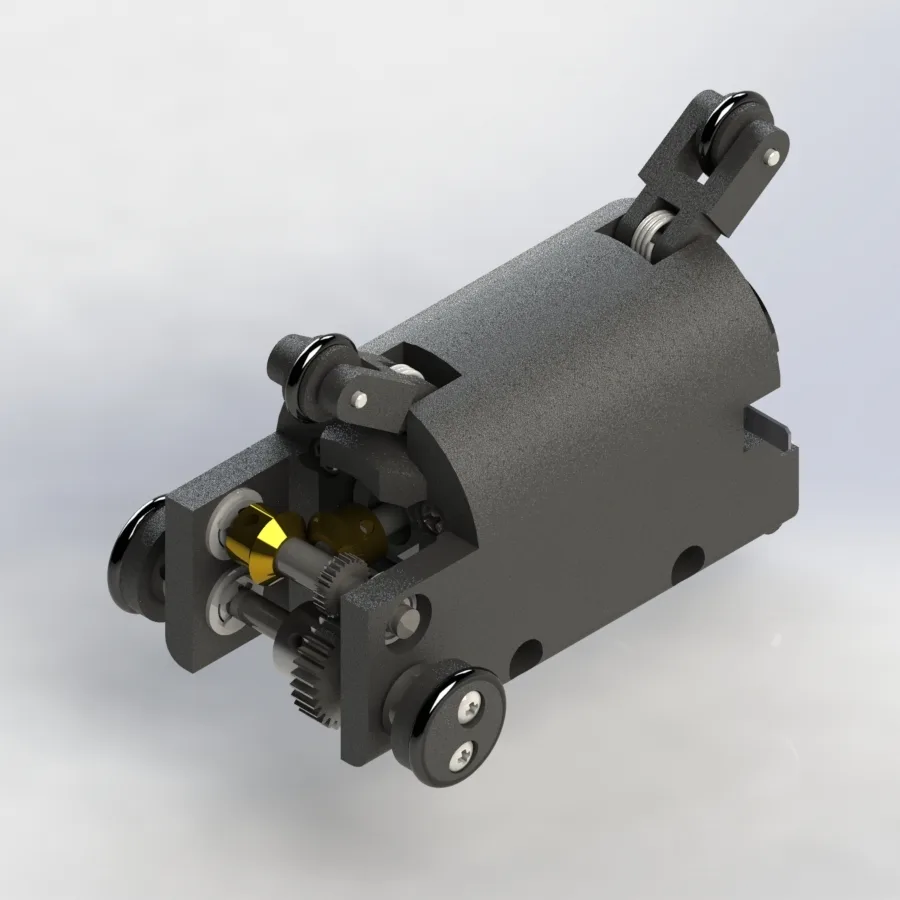
While working on the project, I designed a new mechanism that lets the robot passively change shape, and redesigned the robot to go from fitting 4-inch pipes to 2-inch pipes.
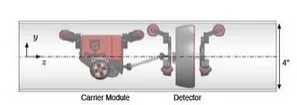
General overview of how the robot works.The detector is the leak-sensing part of the robot, and its outer surface must always stay close to the pipe wall. Spring-loaded legs let it change shape as the pipe diameter changes.How the detector module compensates for a pipe blockage.I redesigned the carrier module to fit pipes half the diameter of the original robot. A motor and a compact gear train move it through the pipe.Side view of the carrier module fitting snugly in its pipe.